High-end Spatial &
Human Intelligence
For Physical AI
Powering AI with embodied spatial and human data and the behavioral-realism benchmark, from environment to behavior.
Space In The Physical And The Virtual World,
Captured At Scale, With Objects.
Every scene object carries mass, friction and material class.
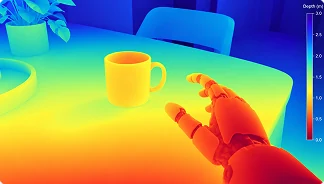
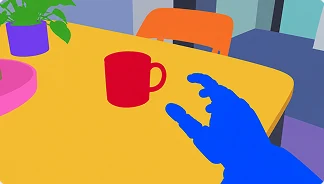
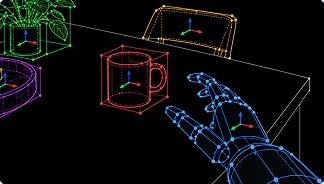
Within These Worlds, We Capture The Synthetic
And Sensory Human Behavior.

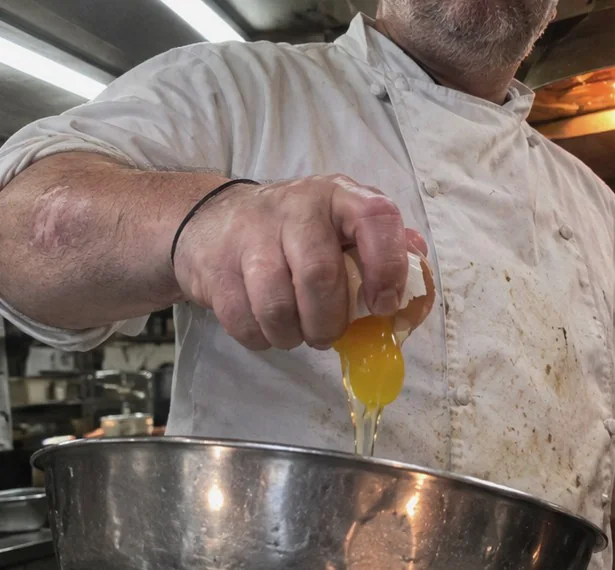
ATTENTION
FINGERS
ACTIVITY
Expert to Agents
Shared capture schemaApplied to all domains
- WWorld & object state
- BBody pose
- HHand kinematics
- AAction stream
- ZGaze & attention
- SSpatial sensors
- ⋮Additional streams
Shared extracted featuresApplied to all domains
- Trajectory smoothness
- Speed profile
- Dwell time
- Action frequency
Skill-specific signalsDomain-specific
Cut angle
Grasp stability
Eye-before-cut
Route-read latency
Grip force
Slip risk
Village Captures Perpetually Licensable Expertise
From The World’s Best People.
EXPERT TALENT
REAL-WORLD SCENARIOS.
Trained VLGE’s Agents On Our Real Human Behavior.
We find the delta, find exactly in which aspects the agent is failing, and improve it.
Human play trains the agent
Joints, contacts, and object poses come from the engine, with no label estimation.
The agent scales the data
Re-runs keep the data human-like, as many times as needed.
The agent generates the long tail
The agent plays and acts inside the simulation for rare scenarios.
Human Build and Play
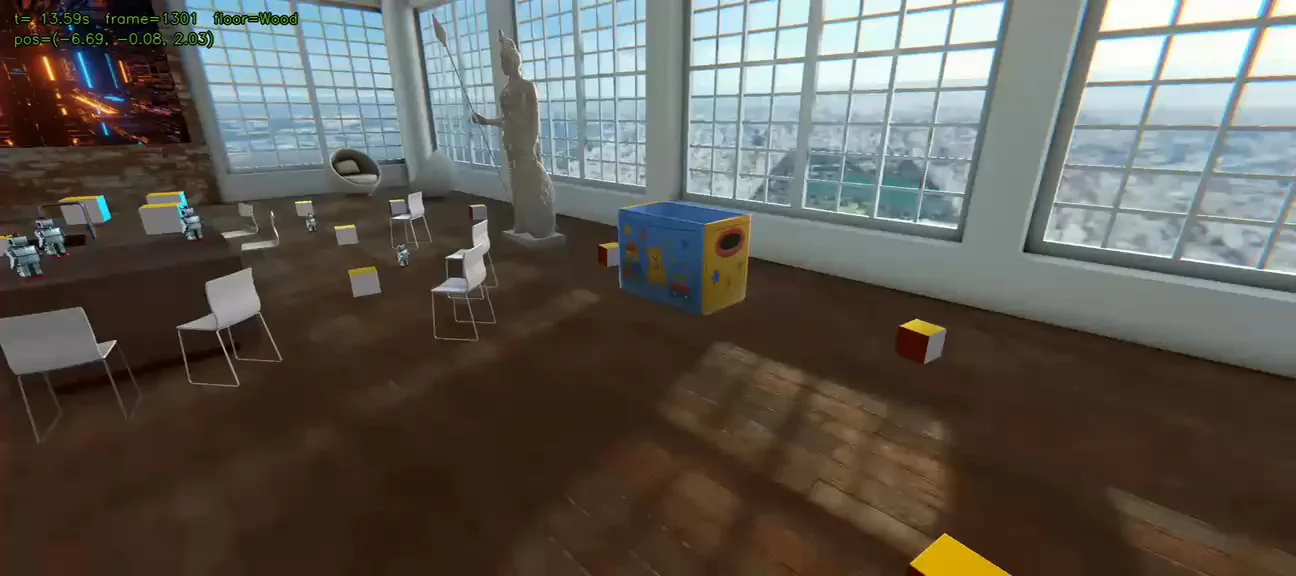
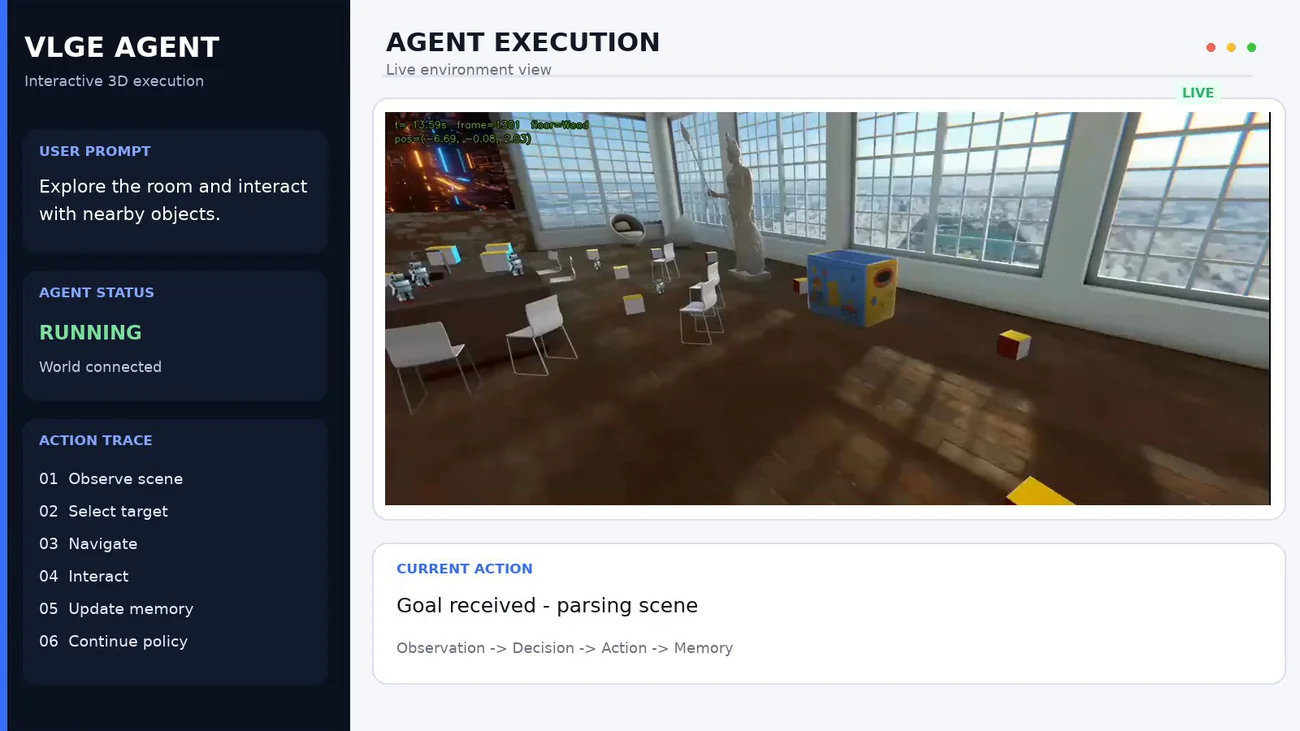
Agent Build and Play
Our Benchmark Shows The Delta In Your Agent Training
And Robotics Deployment.
The benchmark will be used as a reference for AI labs to measure their own agents or world models against it.
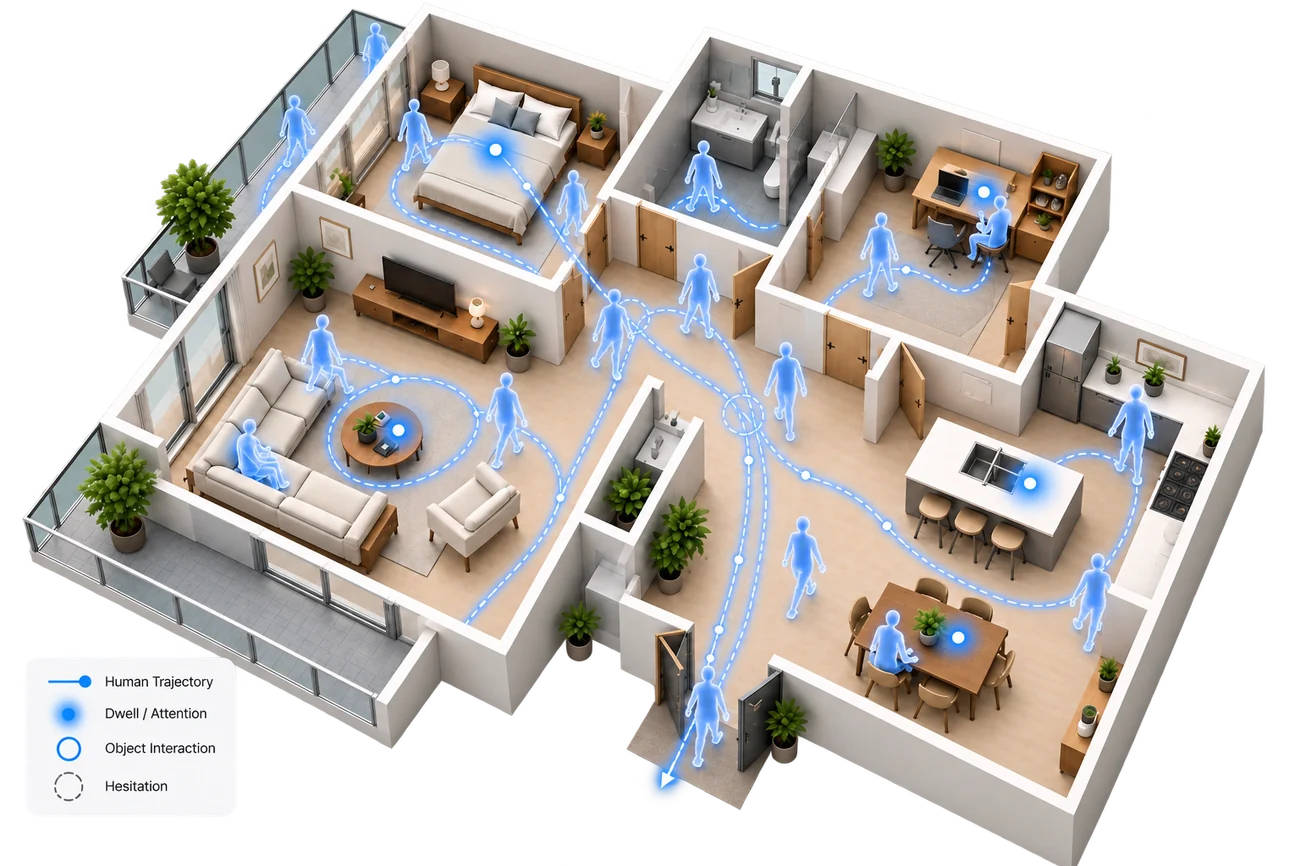
The Human Reference
Many people in the same scenario.
Trajectory, hesitation, decisions, attention.
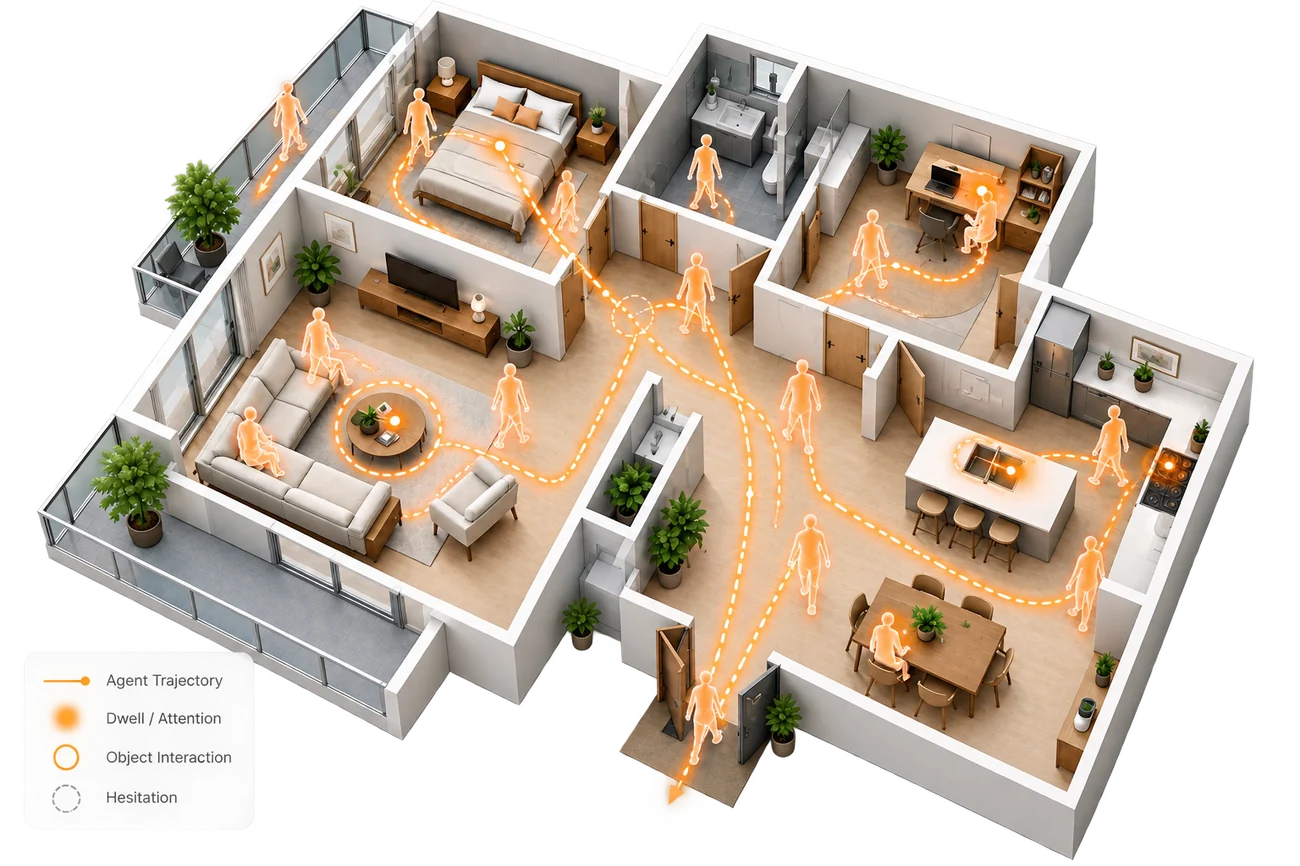
The Agent
Run many times in the same scenario,
measured on the same signals.
Distributional Distance
Compare the two behavioral distributions,
signal by signal.